ARM Cortex-M3 at a Glance
| Parameter |
Details |
| Designer |
ARM (licensed to chip makers such as ST, NXP, Microchip and TI) |
| Architecture |
ARMv7-M |
| Data width |
32-bit RISC core |
| Instruction set |
Thumb and Thumb-2 only (no 32-bit ARM state) |
| Pipeline |
3 stages: fetch, decode, execute |
| Bus design |
Harvard-style: separate I-Code, D-Code and System buses |
| Performance |
1.25 DMIPS/MHz |
| Interrupt controller |
NVIC: up to 240 interrupts, 8 to 256 priority levels |
| Interrupt latency |
12 cycles (zero-wait-state memory) |
| Memory Protection Unit |
Optional, up to 8 regions |
| FPU and DSP |
Not included |
| Debug |
SWD or JTAG with DWT, FPB and ITM (ETM optional) |
| Typical clock speed |
Roughly 24 MHz to 120 MHz, depending on the chip |
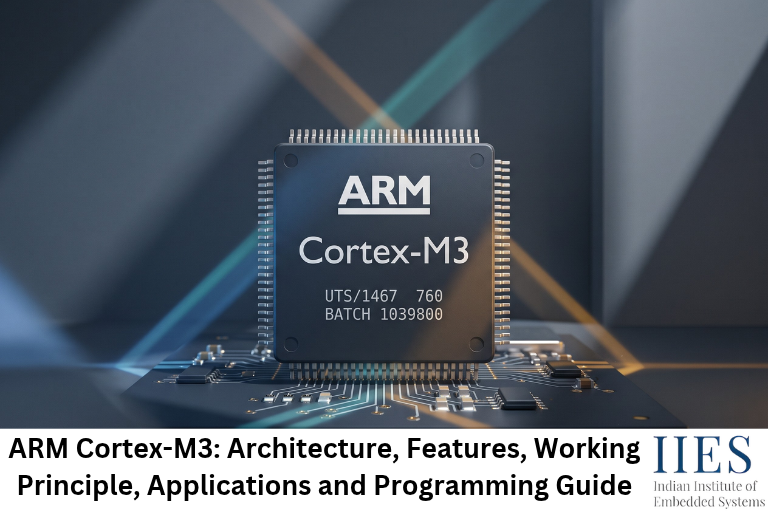
What Is ARM Cortex-M3?
The ARM Cortex-M3 is a licensable 32-bit processor core, built on the ARM architecture and designed for microcontrollers. ARM does not manufacture chips. It sells the design, and companies such as STMicroelectronics, NXP, Microchip and Texas Instruments wrap Flash, SRAM and peripherals around it.
Think of ARM as an architect who sells building plans. Every chip maker builds the same core “floor plan” but adds its own rooms: timers, UART, ADC, USB and CAN.
Key points to remember:
- “M” stands for microcontroller. Cortex-A targets application processors such as phones, Cortex-R targets real-time safety-critical systems, and Cortex-M targets microcontrollers.
- Built to replace the ARM7TDMI. The Cortex-M3 removed its predecessor’s pain points: no ARM/Thumb switching, a built-in interrupt controller, a standard system timer and firmware that can be written entirely in C.
- One core, many chips. Code written against CMSIS ports across STM32, LPC and SAM3 families with minimal changes.
- Where it fits. Cortex-M0/M0+ focus on the lowest cost and power, M3 is the balanced all-rounder, M4 and M7 add DSP and floating-point performance, and M23/M33 add TrustZone security.
ARM Cortex-M3 Architecture
Let’s open the hood. The core looks compact on paper, but every block has a clear job.
1. Three-Stage Pipeline
The ARM Cortex-M3 processes instructions through a three-stage pipeline, much like an assembly line.
- Fetch, Decode, Execute: while one instruction executes, the next is decoded and the one after that is fetched.
- Close to one instruction per cycle for most simple operations, which is how the core reaches 1.25 DMIPS/MHz.
- Branch speculation: the core prefetches the branch target, so loops and function calls rarely stall the pipeline for long.
2. Harvard-Style Bus Interfaces
The Cortex-M3 can fetch an instruction and read data at the same time because they travel on separate buses.
| Bus |
What it carries |
Address region |
| I-Code |
Instruction fetches |
0x00000000 to 0x1FFFFFFF |
| D-Code |
Data reads in the code region (constants, tables) |
0x00000000 to 0x1FFFFFFF |
| System |
Instructions and data in SRAM, peripherals and external memory |
0x20000000 to 0xDFFFFFFF and 0xE0100000 to 0xFFFFFFFF |
| PPB |
Core-private blocks: NVIC, SysTick, debug |
0xE0000000 to 0xE00FFFFF |
I-Code, D-Code and System are
AHB-Lite buses, while the PPB is an
APB bus.
3. Register Set
The Cortex-M3 register set is small. You rarely touch it directly in C, but every debugger shows it, so it pays to know what each register does.
| Register |
Role |
| R0-R7 |
Low registers: general purpose, usable by all instructions |
| R8-R12 |
High registers: general purpose, mainly for 32-bit Thumb-2 instructions |
| R13 (SP) |
Two banked stack pointers: MSP (main) and PSP (process) |
| R14 (LR) |
Link register: return address for calls and exceptions |
| R15 (PC) |
Program counter |
| xPSR |
Flags (N, Z, C, V, Q), active exception number and Thumb state bit |
| PRIMASK |
Blocks all configurable interrupts (used by __disable_irq()) |
| FAULTMASK |
Blocks everything except NMI |
| BASEPRI |
Blocks interrupts at or below a chosen priority level |
| CONTROL |
Selects the privilege level and the stack pointer used in Thread mode |
Pro tip: FreeRTOS on the Cortex-M3 uses BASEPRI for its critical sections, so urgent interrupts keep running while the kernel stays protected. PRIMASK is the blunt tool, BASEPRI the precise one.
4. Operating Modes and Privilege Levels
| Mode |
Runs |
Privilege |
Stack used |
| Thread mode |
Your application code |
Privileged or unprivileged (CONTROL bit 0) |
MSP or PSP (CONTROL bit 1) |
| Handler mode |
Interrupt and exception handlers |
Always privileged |
MSP |
- After reset, the core starts in Thread mode, privileged, using MSP.
- A typical RTOS keeps the kernel on MSP and gives each task its own PSP stack, so one task overflowing its stack does not corrupt the kernel.
- Unprivileged mode plus the MPU stops a faulty task from touching memory it does not own.
5. Memory Map
The Cortex-M3 has a fixed 4 GB linear address space. ARM defines the regions, and each chip maker decides what to place inside them.
| Region |
Address range |
Typical contents |
| Code |
0x00000000 to 0x1FFFFFFF |
Flash, boot memory |
| SRAM |
0x20000000 to 0x3FFFFFFF |
On-chip RAM |
| Peripheral |
0x40000000 to 0x5FFFFFFF |
GPIO, timers, UART, ADC |
| External RAM |
0x60000000 to 0x9FFFFFFF |
Off-chip memory |
| External device |
0xA0000000 to 0xDFFFFFFF |
Off-chip peripherals |
| Private peripheral bus |
0xE0000000 to 0xE00FFFFF |
NVIC, SysTick, SCB, debug |
| Vendor-specific |
0xE0100000 to 0xFFFFFFFF |
Chip-specific features |
Example: on the STM32F103, Flash sits at 0x08000000 (mirrored to 0x00000000 at boot), SRAM starts at 0x20000000 and peripherals start at 0x40000000.
6. Bit-Banding: One Bit, One Address
Bit-banding is a Cortex-M3 feature that lets you read or write a single bit with one ordinary memory access.
Normally, changing one bit takes three steps: read the register, modify the bit, write it back. If an interrupt strikes in the middle and touches the same register, you lose data. Bit-banding removes that risk. Every bit in two 1 MB regions gets its own 32-bit alias address, and writing 0 or 1 to that alias changes exactly that bit in a single atomic operation.
| Region |
Bit-band area |
Alias area |
| SRAM |
0x20000000 to 0x200FFFFF (1 MB) |
0x22000000 to 0x23FFFFFF (32 MB) |
| Peripheral |
0x40000000 to 0x400FFFFF (1 MB) |
0x42000000 to 0x43FFFFFF (32 MB) |
Formula: alias_address = alias_base + (byte_offset x 32) + (bit_number x 4)
A ready-to-use C macro is in the programming section below.
Key Features of ARM Cortex-M3
These are the features that make the Cortex-M3 such a dependable choice for real-time work:
- Thumb-2 instruction set: a mix of 16-bit and 32-bit instructions with the code density of Thumb and performance close to classic ARM.
- Hardware multiply and divide: single-cycle 32×32 multiply, and SDIV/UDIV that finish in 2 to 12 cycles instead of long software routines.
- NVIC: up to 240 interrupts with programmable priorities and nesting handled entirely in hardware.
- Fast, deterministic interrupts: 12-cycle entry, automatic register stacking and tail-chaining keep timing predictable.
- Bit-banding: atomic single-bit access to SRAM and peripherals.
- SysTick timer: a standard 24-bit down-counter in every Cortex-M3, ideal for RTOS ticks and delays.
- Optional MPU: up to 8 protected memory regions for more robust firmware.
- Low-power modes:
WFI and WFE instructions, sleep and deep-sleep modes, and sleep-on-exit for fully interrupt-driven designs.
- Exclusive access instructions:
LDREX and STREX for lock-free semaphores and mutexes.
- Unaligned data access: packed structures and protocol buffers work without byte-by-byte copying.
- Rich debug and trace: hardware breakpoints, watchpoints and
printf-style output over a single SWO pin.
ARM Cortex-M3 Working Principle: From Reset to main() and Beyond
The ARM Cortex-M3 works by reading a vector table, running startup code, executing instructions through its pipeline and reacting to interrupts in hardware. Here is the life of a program, step by step.
- Reset: the core reads two numbers. At address
0x00000000 it finds the initial Main Stack Pointer value, and at 0x00000004 the address of Reset_Handler. These are the first two entries of the vector table, which bootloaders can relocate with the VTOR register.
- Startup code prepares the ground. It copies initialised variables (
.data) from Flash to SRAM, clears .bss, calls SystemInit() to set up the clocks, and finally jumps to main().
- The pipeline keeps instructions flowing. Instructions arrive over I-Code while data moves over D-Code or the System bus, so the core rarely waits on itself.
- An interrupt fires. The NVIC compares its priority with the running code. If it is more urgent, the core automatically pushes eight registers (xPSR, PC, LR, R12, R3, R2, R1, R0) onto the stack while fetching the handler address at the same time. That is why entry takes only 12 cycles.
- The ISR runs in Handler mode. It is a plain C function: no special keywords and no assembly wrapper.
- Return restores everything. A special value called
EXC_RETURN in LR tells the hardware which stack and mode to go back to, and the eight registers are popped automatically.
- Idle? Sleep. When there is nothing to do,
__WFI() pauses the core until the next interrupt, saving power.
Two tricks that make Cortex-M3 interrupts so quick:
- Tail-chaining: if another interrupt is already pending when an ISR finishes, the core skips the pop-and-push and jumps straight to the next handler in 6 cycles.
- Late arrival: if a higher-priority interrupt arrives while the core is still stacking for a lower-priority one, the higher-priority handler runs first with no extra stacking.
Picture the NVIC as a smart receptionist: she knows every visitor’s urgency, lets the most urgent one in first and keeps the queue moving without making anyone fill in the same form twice.
Key Exceptions and Priority Rules
| Exception |
Number |
Priority |
| Reset |
1 |
-3 (fixed, highest) |
| NMI |
2 |
-2 (fixed) |
| HardFault |
3 |
-1 (fixed) |
| MemManage, BusFault, UsageFault |
4, 5, 6 |
Programmable |
| SVCall |
11 |
Programmable |
| PendSV |
14 |
Programmable |
| SysTick |
15 |
Programmable |
| External interrupts (IRQ0 onwards) |
16 and above |
Programmable |
- Lower number means higher priority. Priority 0 beats priority 5.
- Not every priority bit exists. The architecture allows 3 to 8 bits, and STM32 chips implement 4 (16 levels).
- Group and sub-priority. The
PRIGROUP field splits the priority value. Only the group priority decides pre-emption, while sub-priority just orders pending interrupts.
- PendSV and SVCall are an RTOS’s best friends. PendSV (at the lowest priority) performs context switches, and SVC handles system calls.
Thumb-2 Instruction Set in Plain English
The Cortex-M3 executes only Thumb and Thumb-2 instructions, so the compiler can mix 16-bit and 32-bit encodings freely. These are the ones worth knowing:
- IT (If-Then) blocks: conditionally execute up to four instructions without branching.
- CBZ and CBNZ: compare and branch in a single instruction, ideal for null checks.
- BFI, BFC, UBFX, SBFX: insert, clear and extract bit-fields, which is exactly what register and protocol code needs.
- MOVW and MOVT: build any 32-bit constant in two instructions.
- TBB and TBH: table branches that make
switch statements compact and fast.
- SDIV, UDIV, MLA, UMULL: hardware arithmetic that replaces slow library routines.
ARM Cortex-M3 vs Cortex-M0 vs Cortex-M4
| Feature |
Cortex-M0 |
Cortex-M3 |
Cortex-M4 |
| Architecture |
ARMv6-M |
ARMv7-M |
ARMv7E-M |
| Instruction set |
Thumb + small Thumb-2 subset |
Thumb + full Thumb-2 |
Thumb-2 + DSP extensions |
| Performance |
About 0.9 DMIPS/MHz |
1.25 DMIPS/MHz |
1.25 DMIPS/MHz |
| Hardware divide |
No |
Yes |
Yes |
| Interrupts / priority levels |
32 / 4 |
240 / 8 to 256 |
240 / 8 to 256 |
| MPU |
No |
Optional |
Optional |
| Bit-banding |
No |
Yes |
Yes |
| FPU |
No |
No |
Optional (single precision) |
| DSP (SIMD, MAC) |
No |
No |
Yes |
| Best for |
Low-cost, low-power sensors |
Real-time control, RTOS apps |
Audio, filters, motor control |
Which One Should You Pick?
- Cortex-M0/M0+: the lowest cost and power for simple sensors and small appliances.
- Cortex-M3: balanced real-time control for motor drives, industrial I/O and RTOS-based products with modest math.
- Cortex-M4: the right choice when you need DSP instructions or hardware floating point.
For pure integer code, the M3 and M4 perform the same. The M4’s edge appears in signal processing and floating-point work.
Popular ARM Cortex-M3 Microcontrollers
| Vendor |
Chip family |
Notes |
| STMicroelectronics |
STM32F103, STM32F2, STM32L1 |
The F103 runs at 72 MHz and has a huge community (the “Blue Pill” board) |
| NXP |
LPC1768 / LPC17xx |
Up to 100 MHz with Ethernet, USB and CAN |
| Microchip (Atmel) |
SAM3X8E |
84 MHz, the chip on the Arduino Due |
| Texas Instruments |
Stellaris LM3S |
Early Cortex-M3 devices, originally from Luminary Micro |
| Silicon Labs |
EFM32 Gecko families |
Energy-efficient designs |
| Infineon (Cypress) |
PSoC 5LP |
Cortex-M3 plus programmable analog and digital blocks |
Applications of ARM Cortex-M3
The ARM Cortex-M3 shows up wherever a product needs reliable timing, decent processing power and low energy use:
- Industrial automation: motor drives, PLC I/O modules, process controllers and sensor hubs.
- Automotive electronics: CAN-connected body control, lighting and sensor modules.
- Consumer products: washing machines, air conditioners, power tools and remote controls.
- Medical devices: portable monitors and diagnostic instruments that need predictable response times.
- IoT and smart metering: sensor nodes, gateways and energy meters with Zigbee, LoRa or BLE modules.
- Robotics, drones and 3D printers: motion control, stepper drivers and flight controllers.
- Networking: Ethernet, USB and CAN gateways and protocol converters.
- Power electronics: inverters, UPS units, battery management systems and LED drivers.
How to Program ARM Cortex-M3: A Practical Guide
What You Need
- A board: an STM32F103 “Blue Pill” is cheap and popular, but any Cortex-M3 board works.
- A programmer/debugger: ST-Link (SWD), J-Link or CMSIS-DAP.
- A toolchain: STM32CubeIDE, Keil MDK, IAR EWARM, or the open-source Arm GNU Toolchain (
arm-none-eabi-gcc) with OpenOCD and GDB.
- Libraries: CMSIS core headers plus your vendor’s device header or HAL.
The Programming Workflow in 6 Steps
- Create a project for your exact chip (startup file, linker script and CMSIS headers).
- Confirm the clock setup (
SystemInit() normally configures 72 MHz on the STM32F103).
- Enable the peripheral clock in the RCC registers.
- Configure the GPIO or peripheral registers.
- Write your logic and use interrupts for time-critical events.
- Build, flash over SWD and debug with breakpoints.
Example 1: Blink an LED Using SysTick (STM32F103, PC13)
#include    /* use  with STM32Cube */

volatile uint32_t ms_ticks = 0;

void SysTick_Handler(void)               /* runs every 1 ms */
{
    ms_ticks++;
}

static void delay_ms(uint32_t ms)
{
    uint32_t start = ms_ticks;
    while ((ms_ticks - start) < ms) { } /* safe even when the counter wraps */ } int main(void) { SystemCoreClockUpdate(); SysTick_Config(SystemCoreClock / 1000); /* 1 ms tick */ RCC->APB2ENR |= RCC_APB2ENR_IOPCEN;       /* clock for GPIOC */
    GPIOC->CRH &= ~(GPIO_CRH_MODE13 | GPIO_CRH_CNF13);
    GPIOC->CRH |= GPIO_CRH_MODE13_1;          /* PC13: output, 2 MHz, push-pull */

    while (1)
    {
        GPIOC->ODR ^= GPIO_ODR_ODR13;         /* toggle the on-board LED */
        delay_ms(500);
    }
}
Why it works:
SysTick_Config() comes from CMSIS and sets up a 1 ms interrupt.volatile stops the compiler from caching a variable that an ISR changes.- Subtracting
start from ms_ticks stays correct even when the counter overflows.
Example 2: Atomic Bit Access with Bit-Banding
#define BB_ALIAS(base, alias, addr, bit) (*(volatile uint32_t *)((alias) + (((uint32_t)(addr) - (base)) << 5) + ((uint32_t)(bit) << 2))) #define BITBAND_PERI(addr, bit) BB_ALIAS(0x40000000UL, 0x42000000UL, addr, bit) #define BITBAND_SRAM(addr, bit) BB_ALIAS(0x20000000UL, 0x22000000UL, addr, bit) BITBAND_PERI(&GPIOC->ODR, 13) = 1;   /* set PC13 in one atomic write */
BITBAND_PERI(&GPIOC->ODR, 13) = 0;   /* clear PC13 */

volatile uint32_t flags;
BITBAND_SRAM(&flags, 3) = 1;         /* set bit 3 of a shared flag word */
Bit-banding is available on the Cortex-M3 and Cortex-M4, so code that uses it will not port to cores without it, such as the Cortex-M0.
Example 3: Enabling an Interrupt with NVIC
Every interrupt follows the same pattern: configure the peripheral to raise it, set the priority, enable it in the NVIC and keep the ISR short. This example assumes PA0 and EXTI line 0 are already configured.
volatile uint8_t button_pressed = 0;

void EXTI0_IRQHandler(void)
{
    if (EXTI->PR & EXTI_PR_PR0)
    {
        EXTI->PR = EXTI_PR_PR0;       /* clear the pending flag first */
        button_pressed = 1;           /* set a flag, do the work in main() */
    }
}

void nvic_setup(void)
{
    NVIC_SetPriority(EXTI0_IRQn, 5);  /* smaller number = higher priority */
    NVIC_EnableIRQ(EXTI0_IRQn);
}
Debugging Tips
- HardFault? Read the Configurable Fault Status Register (
SCB->CFSR) and the stacked PC to find the exact instruction that failed.
- No UART for logs? Use ITM/SWO for
printf-style output if your debug probe and board expose the SWO pin.
- Need exact timing? The DWT cycle counter (
DWT->CYCCNT) measures code in clock cycles.
Common Mistakes to Avoid
- Forgetting the peripheral clock: registers ignore your writes until the RCC clock is enabled.
- Not clearing the interrupt flag: the ISR fires again and again.
- Missing
volatile: variables shared between an ISR and main() need it.
- Heavy work inside ISRs: set a flag, then process it in the main loop.
- Priority confusion: a smaller number means higher urgency.
- Tiny stacks: an undersized stack usually shows up as a mysterious HardFault.
For more habits that keep firmware reliable, see
embedded C best practices.
Advantages and Limitations of ARM Cortex-M3
Advantages
- Excellent performance per watt for real-time control
- Deterministic, low-latency interrupt handling
- Compact code thanks to Thumb-2, which keeps Flash costs down
- A huge ecosystem: CMSIS, FreeRTOS, Zephyr, Keil RTX and vendor HALs
- Low cost, wide availability and easy debugging
Limitations
- No hardware FPU, so floating-point math runs in software and is much slower
- No DSP or SIMD instructions
- No built-in cache or TrustZone, so it is not aimed at high-end or security-critical designs
- The MPU is optional, so not every chip has one
Conclusion: Key Takeaways
The ARM Cortex-M3 earned its place by doing the basics extremely well. Keep these points handy:
- It is a 32-bit ARMv7-M core with a 3-stage pipeline, Thumb-2 and Harvard-style buses.
- The NVIC gives fast, nested, predictable interrupts, with 12-cycle entry and tail-chaining.
- Bit-banding, SysTick and the optional MPU make firmware safer and simpler.
- Startup is simple: read the stack pointer and reset vector, run the startup code, then
main().
- Pick M0 for cost, M3 for balanced control and M4 for DSP and floating point.
Your next step: flash the SysTick example on a Cortex-M3 board, then extend it with a button interrupt. Once that blink works, you are already thinking like a firmware engineer.